ProjectsROS2YOLOv8PythonComputer Vision
ROS2 YOLOv8
Connecting camera capture and object detection through ROS2.
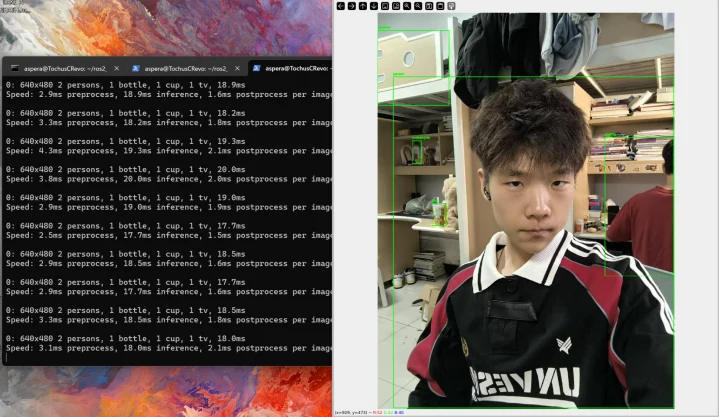
Node-based vision
The project splits camera capture and object detection into ROS2 nodes. A capture node publishes camera frames, and a receiver uses YOLOv8 to detect objects and display annotated results.
Workflow
Build the package in a ROS2 workspace, then start the capturer and detector nodes. The repository includes launch instructions and a screenshot of a running detection session.